

 GPS & GNSS
 Lidar scanning
 Total Station
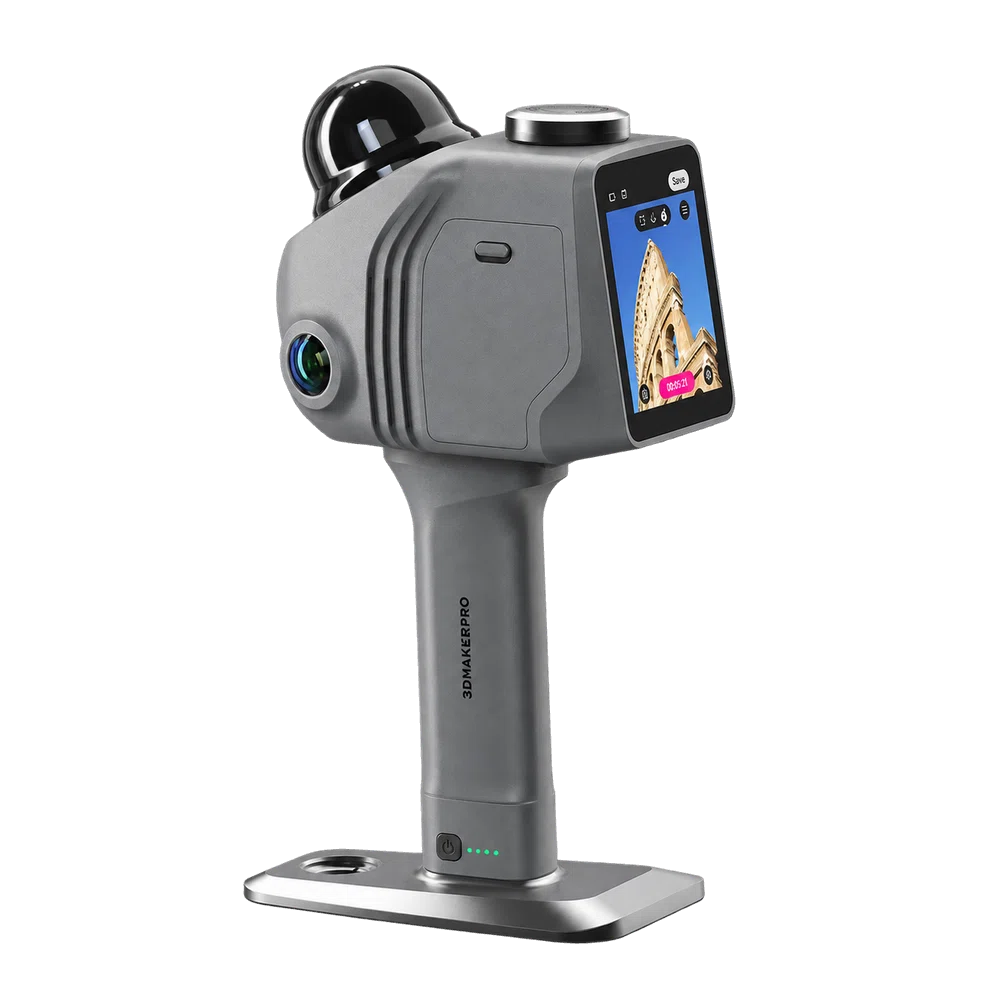
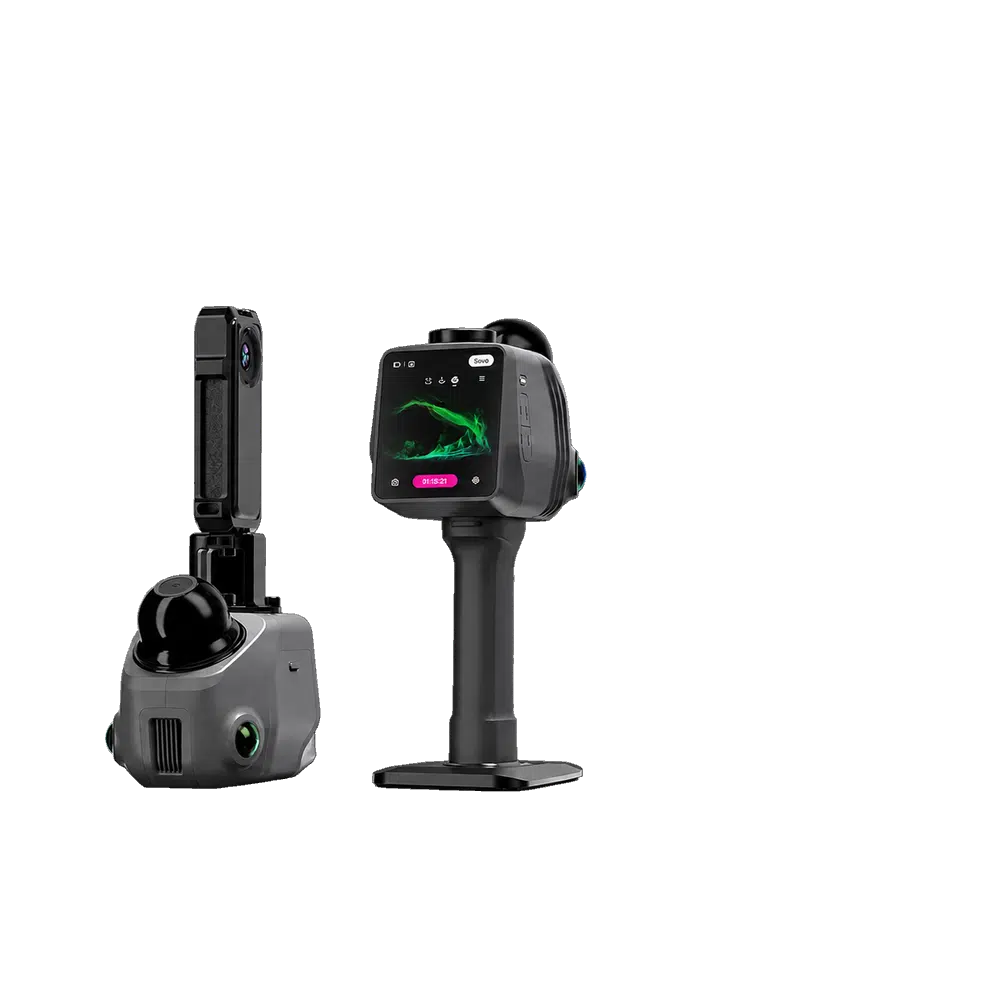
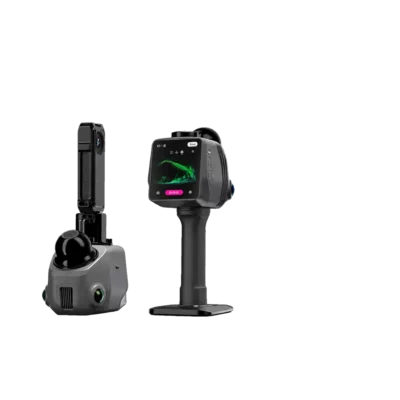
3DMakerpro Raven Max RTK SLAM LiDAR 3D Scanner with Dual Cameras
Get the best price for your setup
Contact our experts for the best possible price and configuration.
- Fast response
- Expert configuration advice
- No overpaying for features you do not need
The 3DMakerpro Raven Max RTK is a portable SLAM LiDAR 3D scanner with RTK GNSS positioning, designed for surveying, construction, infrastructure mapping and GIS applications. Combining high-speed laser scanning with dual 12 MP colour cameras and an included RTK positioning kit, it allows professionals to capture detailed 3D point clouds and connect their measurements to real-world geographical coordinates.
With a scanning range of up to 100 metres, a specified LiDAR accuracy of 2 cm at 10 metres and a capture rate of 150,000 points per second, the Raven Max RTK makes it easier to document buildings, construction sites and large outdoor environments. The 360° horizontal scanning system, integrated AMOLED display and removable battery grip support efficient mobile fieldwork, while RayStudio software provides point cloud processing, RTK data integration and 3D visualisation. Centimetre-level GNSS positioning is possible with suitable RTK corrections and satellite reception.
3DMakerpro Raven Max RTK Highlights
| Scanning technology | Handheld SLAM LiDAR 3D scanning |
|---|---|
| RTK positioning | Included RTK GNSS kit for georeferenced scanning and centimetre-level positioning under suitable conditions |
| LiDAR accuracy | 2 cm at 10 m; 3 cm at 20 m; 5 cm at 40 m |
| Scanning range | Up to 100 m; 40–50 m detection radius depending on target reflectivity |
| Point cloud capture | 150,000 points per second |
| Field of view | 360° horizontal and 40° vertical |
| Colour cameras | Dual 12 MP cameras with 1/2-inch sensors |
| Display | 3.9-inch AMOLED |
| Battery | Removable 12,000 mAh battery grip; up to 2 hours operation |
| Scanner weight | 1.1 kg excluding RTK accessories |
| Data export | LAS, PCD, PLY, OBJ, E57 and XYZ |
You may also like…
Lidar & 3D scanning
3DMakerpro Raven Handheld SLAM LiDAR 3D Scanner with 100m Range
Lidar & 3D scanning
3DMakerpro Raven Max SLAM LiDAR 3D Scanner with Dual Cameras
Valued customers:

Find RTK Networks
Search NTRIP providers and connect to reliable RTK correction services.
Description
3DMakerpro Raven Max RTK Handheld SLAM LiDAR 3D Scanner
The 3DMakerpro Raven Max RTK is a professional handheld LiDAR 3D scanner that combines SLAM mapping, dual 12 MP colour cameras and RTK GNSS positioning. Designed for land surveyors, construction professionals, civil engineers and GIS specialists, it allows users to capture detailed three-dimensional environments while connecting scan data to real-world geographical coordinates.
With a maximum scanning range of 100 metres, a measurement rate of up to 150,000 points per second and a specified LiDAR accuracy of 2 cm at 10 metres, the Raven Max RTK provides a practical solution for documenting buildings, construction sites, industrial facilities and outdoor infrastructure. Its lightweight design and mobile scanning workflow make it possible to collect detailed spatial information while walking through the project area.
Unlike the standard Raven and Raven Max, this configuration includes an RTK GNSS positioning kit. This makes it particularly suitable for mapping projects where point clouds need to be associated with geographical coordinates rather than remaining only in a local scanning coordinate system.
RTK GNSS Positioning for Georeferenced 3D Mapping
The main advantage of the Raven Max RTK is its ability to combine LiDAR scanning with Real-Time Kinematic (RTK) GNSS positioning. With suitable correction data and satellite reception, RTK technology can provide centimetre-level positioning information that helps connect captured 3D environments to geographical coordinates.
For land surveyors and GIS professionals, this is valuable when documenting infrastructure, outdoor sites and physical assets that need to be located within a wider mapping project. Instead of working exclusively with a locally positioned point cloud, users can process RTK observations to support the geographical positioning of their scan data.
The system supports positioning workflows using RTK differential correction services and compatible GNSS base station data. RayStudio can process positioning information together with the scanned point cloud to support georeferenced 3D datasets.
Accurate RTK positioning requires suitable satellite visibility, correction data and correct processing settings. Buildings, trees, tunnels and other obstructions can affect GNSS reception. For projects requiring verified survey coordinates, independent control points and accuracy checks remain important.
Mobile SLAM LiDAR Scanning Without Repeated Scanner Setups
The Raven Max RTK uses Simultaneous Localisation and Mapping (SLAM) technology to capture the geometry of an environment while the operator moves. Instead of measuring every feature individually or repeatedly setting up a stationary scanner, users can walk through a building, construction site or industrial area while collecting continuous LiDAR measurements.
The scanner uses its sensor data to estimate movement and connect successive measurements into a three-dimensional point cloud. This approach is especially useful for corridors, warehouses, building interiors and other complex spaces where many surfaces and structural features need to be documented.
For construction teams, mobile scanning can simplify the process of recording existing conditions before renovation or installation work. Surveyors can use the resulting point cloud to examine site geometry, while engineers can review the relationships between visible structures, equipment and surrounding spaces.
Good scanning technique remains important. Maintaining a steady walking speed, scanning overlapping areas and following suitable loop paths can help improve SLAM alignment and reduce accumulated mapping drift.
Centimetre-Level LiDAR Measurement Accuracy
The Raven Max RTK offers specified LiDAR measurement accuracy of 2 cm at 10 metres, 3 cm at 20 metres and 5 cm at 40 metres. These specifications make it useful for collecting building geometry, structural features, visible installations and other spatial information for technical documentation and 3D modelling.
In practical fieldwork, the point cloud can provide a detailed reference of the measured environment. Engineers can examine spatial relationships between structures, while building professionals can use scan data to support renovation planning, as-built documentation and preparation of CAD or BIM models.
It is important to distinguish between LiDAR measurement accuracy and RTK GNSS positioning accuracy. LiDAR accuracy describes the measurement of surfaces at specified distances, while RTK positioning relates to the geographical location of the scanner. The final accuracy of a georeferenced point cloud depends on both systems, as well as SLAM alignment, processing and field conditions.
Up to 100 Metres Scanning Range
With a maximum specified scanning range of 80 to 100 metres, the Raven Max RTK can capture spatial information across indoor environments and larger outdoor areas. The effective detection radius is approximately 40 metres for surfaces with 10% reflectivity and 50 metres for surfaces with 80% reflectivity.
This range is useful for documenting building exteriors, construction areas, infrastructure features, industrial halls and open sites. Professionals can collect measurements of surrounding surfaces without needing to approach every object directly.
The actual scanning distance depends on surface reflectivity and environmental conditions. Dark surfaces and difficult viewing angles may produce shorter measurement distances than bright, reflective targets.
360-Degree LiDAR Coverage and High-Density Point Clouds
The scanner provides a 360° horizontal field of view and a 40° vertical field of view, allowing it to record surfaces in every horizontal direction as the operator moves through the environment.
With up to 150,000 points captured per second, the Raven Max RTK collects detailed geometry from walls, floors, columns, machinery, terrain features and other visible objects. The resulting point cloud provides a digital representation that can be reviewed and processed after the scanning session.
For building documentation, this helps capture relationships between architectural elements. In outdoor surveying, the scanner can collect visible site features and structural geometry for spatial mapping applications. Additional scanning passes may be necessary to capture elevated surfaces or areas outside the scanner’s vertical field of view.
Dual 12 MP Cameras for Colour 3D Documentation
The Raven Max RTK features two 12 MP colour cameras with 1/2-inch sensors. These cameras capture visual information alongside the LiDAR measurements, allowing users to produce colourised point clouds and visually detailed 3D models.
Colour data makes scanned environments easier to interpret. Building surveyors can identify different materials, doors, windows and surface features, while construction teams can document visible installations and existing conditions. For industrial facilities, colour information helps distinguish machinery, structural elements and surrounding equipment.
The dual-camera configuration also supports realistic 3D visualisation workflows, including Gaussian Splatting. This is particularly useful for digital twins, architectural presentations and projects where users need both technical geometry and a recognisable representation of the physical environment.
Portable Design with Integrated AMOLED Display
The Raven Max RTK uses the compact Raven Max scanner body, weighing approximately 1.1 kg before RTK accessories. Its portable design makes it manageable for field teams working across multiple locations or moving through large buildings and construction environments.
An integrated 3.9-inch AMOLED display allows operators to control scanning functions and monitor data collection directly on the device. An eight-core 2.4 GHz processor supports onboard operation, while expandable TF card storage allows captured scanning data to be saved for later processing.
The scanner uses a 905 nm Class 1 laser system compliant with IEC 60825-1:2014. Its standalone operating design reduces the need to carry a laptop during routine data acquisition.
Removable Battery for Extended Fieldwork
The Raven Max RTK includes a removable 12,000 mAh battery grip with up to two hours of operation under specified conditions. The replaceable battery design helps teams organise longer field sessions by using additional compatible battery grips when required.
External power is also supported for suitable operating configurations. The scanner includes USB Type-C connectivity, USB-C power delivery up to 65 W and Wi-Fi 5 connectivity for communication and data transfer.
For surveyors and construction teams, these features provide flexibility when scanning multiple buildings, carrying out site documentation or working at locations without convenient access to mains power.
RayStudio Software for RTK Processing and 3D Point Clouds
Captured scanning data can be processed using RayStudio, the dedicated software for 3DMakerpro spatial scanners. RayStudio supports point cloud processing, filtering, colourisation, 3D visualisation and the integration of positioning information.
For RTK workflows, the software supports processing data collected with the RTK-equipped scanner. Depending on the selected workflow, geographical positioning can use recorded GPS information, compatible base station observation files or RTK differential correction data.
Once processed, the point cloud can be reviewed, cleaned and prepared for further use. Supported export formats include LAS, PCD, PLY, OBJ, E57 and XYZ, providing flexibility for transferring spatial information into compatible CAD, GIS, point cloud and 3D modelling applications.
RayStudio also supports Gaussian Splatting for realistic visual representations of scanned environments. Desktop processing requires a compatible Windows computer, with an NVIDIA graphics card required for Gaussian Splatting workflows. Final CAD drawings, BIM models or other engineering deliverables may require additional specialist software and processing.
Applications in Surveying, Construction and GIS
The combination of handheld SLAM LiDAR scanning and RTK positioning makes the Raven Max RTK particularly useful for professionals who need detailed three-dimensional measurements connected to a wider spatial reference.
- Land surveying and topographical mapping: Capture visible terrain features, structures and site geometry as point clouds that can be georeferenced and checked against survey control.
- Construction and civil engineering: Document existing conditions, building geometry, infrastructure features and site progress for planning and engineering reference.
- GIS and asset management: Collect spatial information about visible assets and prepare georeferenced 3D datasets for integration into compatible GIS workflows.
- Architecture and renovation: Scan building interiors, facades and surrounding areas to support existing-condition documentation and 3D modelling.
- Industrial inspection: Record complex machinery areas, equipment layouts and installations for maintenance planning and facility documentation.
- Infrastructure mapping: Capture bridges, tunnels, roadsides and other accessible structural environments, using appropriate control where GNSS signals are restricted.
Additional Mounting Options for Mobile Mapping
The Raven Max RTK supports optional mounting accessories for different data collection methods, including backpack, bicycle, vehicle and drone configurations. These accessories can extend its use beyond ordinary handheld scanning and allow data collection along larger routes or in areas where carrying the scanner by hand is impractical.
For drone applications, the mounting arrangement, payload capacity, power supply and positioning setup must be suitable for the aircraft and intended mission. The scanner operates independently, so integration with a drone’s flight control system should not be assumed.
In environments with poor satellite visibility, such as dense urban areas, tunnels or enclosed industrial spaces, RTK positioning performance may be limited. Additional survey control or point cloud registration methods may be needed.
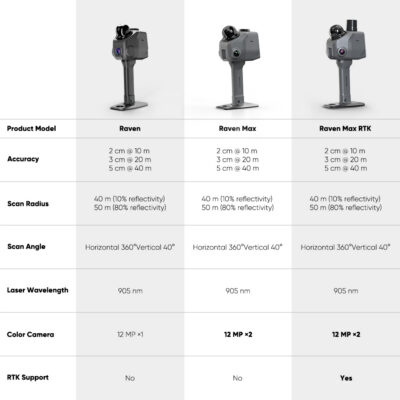
Raven Max RTK Compared with Raven and Raven Max
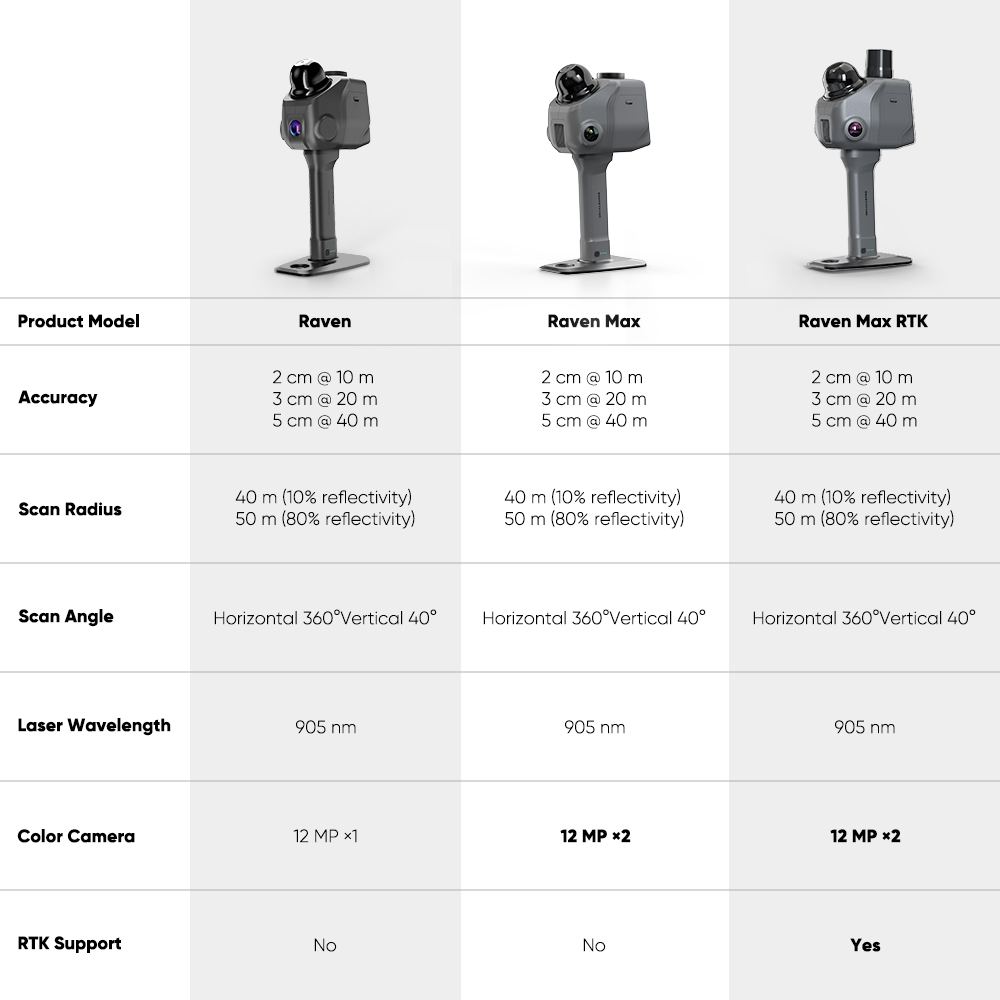
The 3DMakerpro Raven series includes three configurations based on the same core SLAM LiDAR scanning system. The standard Raven has one 12 MP colour camera, while the Raven Max features two 12 MP cameras for additional visual capture.
The Raven Max RTK combines the dual-camera Raven Max scanner with an included RTK GNSS positioning kit. This makes it the appropriate configuration for users who want to connect their scanning data to geographical coordinates using GNSS positioning workflows.
All three models share the same stated maximum LiDAR scanning range, point capture rate and distance-dependent LiDAR accuracy. The principal difference is therefore the camera configuration and the availability of RTK GNSS positioning.
Included Raven Max RTK Equipment
The Raven Max RTK configuration includes the Raven Max LiDAR scanner, RTK positioning kit, removable battery grip, mounting base, protective cover, TF memory card, card reader and carrying case. This equipment provides the main components needed to begin scanning and organise data transfer and transport.
Projects requiring centimetre-level geographical positioning also need a suitable RTK correction workflow, compatible reference data and adequate GNSS reception. The appropriate correction method depends on the location and project requirements.
3DMakerpro Raven Max RTK at Global GPS Systems
At Global GPS Systems, we help land surveyors, civil engineers, construction companies and GIS specialists choose equipment suited to their measurement and mapping projects. The 3DMakerpro Raven Max RTK is particularly relevant for professionals looking to combine portable LiDAR scanning with geographical positioning.
Whether you are documenting infrastructure, mapping a construction site or preparing georeferenced 3D data for engineering work, our team can help you understand the RTK setup, compatible correction services, software requirements and suitable accessories. We can also advise on additional GNSS surveying equipment and control methods for projects where coordinate accuracy needs to be independently verified.
Datasheets & Manuals
Specifications
3DMakerpro Raven Max RTK LiDAR 3D Scanner Specifications
General Specifications
| Manufacturer | 3DMakerpro |
|---|---|
| Model | Raven Max RTK |
| Product Series | Raven |
| Product Type | Portable handheld LiDAR 3D spatial scanner with RTK GNSS positioning |
| Scanning Technology | LiDAR with enhanced SLAM (Simultaneous Localization and Mapping) |
| Positioning Technology | RTK GNSS and multi-sensor SLAM |
| RTK GNSS Kit | Included |
| Absolute Positioning | Centimeter-level positioning under suitable RTK correction and GNSS reception conditions |
| Color Camera Configuration | Dual integrated 12 MP cameras |
| Maximum Scanning Range | 100 m |
| Maximum Scanning Radius | 50 m at 80% target reflectivity |
| Point Cloud Acquisition Rate | 150,000 points/second |
| Scanning Field of View | 360° horizontal × 40° vertical |
| Color Reconstruction | RGB point clouds, polygonal models and 3D Gaussian Splatting |
| Integrated Display | 3.9-inch AMOLED touchscreen |
| Operating Method | Standalone handheld scanning and compatible accessory-mounted scanning |
| Operating Environments | Indoor and outdoor environments |
| Primary Applications | 3D surveying, georeferenced mapping, construction, architecture, GIS, infrastructure documentation, BIM, digital twins, geological mapping and 3D visualization |
RTK GNSS Positioning and Georeferencing
| RTK GNSS Support | Included with the Raven Max RTK configuration |
|---|---|
| RTK Technology | Real-Time Kinematic GNSS |
| RTK Positioning Hardware | Dedicated RTK expansion kit |
| RTK Positioning Accuracy | Centimeter-level absolute positioning; exact horizontal and vertical accuracy specifications are not published |
| Absolute Geographic Positioning | Supported |
| Georeferenced Point Clouds | Supported through the RTK-enabled positioning workflow |
| Geographic Position Data | Latitude, longitude and altitude |
| GNSS-Assisted SLAM | Supported |
| RTK-Assisted Mapping | Supported for outdoor spatial data collection |
| Real-World Coordinate Association | Supported for scanned 3D spatial data |
| Relative and Absolute Positioning | SLAM-based relative mapping combined with RTK-based absolute positioning |
| RTK Correction Requirement | Suitable GNSS correction data and reception conditions are required for centimeter-level positioning |
| GNSS Constellations | Not specified by manufacturer |
| GNSS Frequency Bands | Not specified by manufacturer |
| RTK Initialization Time | Not specified by manufacturer |
| RTK Correction Protocols | Not specified by manufacturer |
| Coordinate Reference Systems | Specific supported coordinate systems and transformations are not published |
| RTK Configuration Availability | Factory-bundled with Raven Max RTK; standalone RTK module availability is not offered by the manufacturer |
| Indoor GNSS Availability | GNSS positioning depends on satellite visibility; SLAM scanning can operate without GNSS positioning |
LiDAR Scanning Performance
| Scanning Principle | Laser-based spatial distance measurement with SLAM reconstruction |
|---|---|
| LiDAR Scanning Range | 80–100 m |
| Maximum Specified Range | 100 m |
| Scanning Radius at 10% Reflectivity | 40 m |
| Scanning Radius at 80% Reflectivity | 50 m |
| Minimum Scanning Distance | 0.5 m |
| Horizontal Field of View | 360° |
| Vertical Field of View | 40° |
| Combined Scanning Field of View | 360° × 40° |
| Point Cloud Acquisition Rate | 150,000 points/second |
| Point Cloud Acquisition Rate in kpts/s | 150 kpts/s |
| Laser Wavelength | 905 nm |
| Laser Safety Classification | Class 1 |
| Laser Safety Standard | IEC 60825-1:2014 |
| Real-Time 3D Point Cloud Acquisition | Supported |
| Continuous Mobile Scanning | Supported |
| RGB Point Cloud Acquisition | Supported using integrated dual-camera imaging |
| Monochrome Point Cloud Acquisition | Supported |
| Large-Scale Spatial Scanning | Supported |
| Indoor Scanning | Supported |
| Outdoor Scanning | Supported |
| Low-Light LiDAR Scanning | Supported; laser distance measurement does not rely on visible ambient lighting |
| Scanning Performance Conditions | Maximum range and point cloud quality depend on target reflectivity, geometry, environmental conditions and scanning technique |
LiDAR Measurement Accuracy
| Measurement Distance | Specified Accuracy | Equivalent in Millimeters |
|---|---|---|
| 10 m | 2 cm | 20 mm |
| 20 m | 3 cm | 30 mm |
| 40 m | 5 cm | 50 mm |
LiDAR measurement accuracy and RTK absolute positioning accuracy are separate specifications. The listed LiDAR values describe scanning performance at the specified distances. RTK accuracy describes the positioning of acquired spatial data in a geographic reference system.
Optical Camera and Imaging System
| Camera Configuration | Dual integrated RGB camera system |
|---|---|
| Number of Color Cameras | 2 |
| Resolution per Camera | 12 megapixels |
| Combined Camera Configuration | 2 × 12 MP |
| Camera Image Sensor Size | 1/2 inch |
| Camera Lens Type | Fisheye imaging system |
| Color Imaging | 4K true-color capture |
| Automatic Exposure Adjustment | Supported for varying indoor and outdoor lighting conditions |
| HDR Mode | Not supported |
| RGB Point Cloud Colorization | Supported |
| Color Texture Acquisition | Supported |
| Image-Assisted SLAM | Supported |
| Image-Based 3D Reconstruction | Supported |
| Gaussian Splatting Image Acquisition | Supported |
| External 360° Camera Compatibility | Supported with optional 360 Camera Kit |
| Compatible 360° Camera Models | Insta360 X4 and Insta360 X5 |
| Low-Light Color Capture | Dependent on available illumination and camera exposure conditions |
SLAM and Multi-Sensor Tracking
| SLAM Technology | Enhanced Simultaneous Localization and Mapping |
|---|---|
| Sensor Fusion | LiDAR point cloud, optical image, IMU and GNSS positioning data |
| LiDAR-Based Tracking | Supported |
| Image-Assisted Tracking | Supported |
| Inertial Measurement Unit | IMU data incorporated into SLAM processing |
| GNSS-Assisted Tracking | Supported with included RTK positioning configuration |
| Real-Time Spatial Mapping | Supported |
| Continuous Trajectory Estimation | Supported |
| Motion-Related Drift Reduction | Enhanced SLAM combines multiple sensor inputs to reduce point cloud drift during scanner movement |
| Scan Alignment | SLAM-based spatial alignment |
| Relative Position Tracking | Supported |
| Absolute Position Tracking | Supported using RTK GNSS when appropriate correction data and satellite signals are available |
| GNSS-Free Scanning | Supported using SLAM-based mapping |
| Indoor SLAM Mapping | Supported |
| Outdoor Georeferenced Mapping | Supported |
Integrated Processing and Storage
| Integrated Processor | 8-core processor |
|---|---|
| Processor Clock Speed | 2.4 GHz |
| Specified Internal Memory / Storage | 32 GB |
| Expandable Storage | Supported |
| Expansion Media | TF card (microSD) |
| Included TF Card Capacity | 128 GB |
| Onboard Data Acquisition | Supported |
| Onboard SLAM Processing | Supported |
| Real-Time Scan Processing | Supported |
| Standalone Field Scanning | Supported without continuous connection to a desktop computer |
| Desktop Post-Processing | Supported through 3DMakerpro RayStudio |
Display and User Interface
| Display Size | 3.9 inches |
|---|---|
| Display Technology | AMOLED |
| Touchscreen Interface | Supported |
| Integrated Display | Yes |
| On-Device Scanner Controls | Supported |
| Real-Time Scan Monitoring | Supported |
| Point Cloud Preview | Supported |
| Scanner Status Monitoring | Supported |
| Standalone Operation | Supported using the integrated screen and scanner controls |
Connectivity and Interfaces
| USB Data Interface | 1 × USB Type-C |
|---|---|
| Power Delivery Interface | 1 × USB Type-C with 65 W USB Power Delivery |
| Wireless Connectivity | Wi-Fi |
| Wi-Fi Standard | Wi-Fi 5 (IEEE 802.11ac) |
| Removable Storage Interface | TF card (microSD) |
| Computer Data Transfer | Supported through compatible USB and removable storage workflows |
| Included Card Reader | TF card reader |
| External Power Supply | Supported |
| RTK GNSS Expansion | Included with Raven Max RTK configuration |
| External Panoramic Camera Expansion | Supported with compatible optional accessories |
Battery and Power Supply
| Battery Type | Rechargeable removable battery grip |
|---|---|
| Battery Capacity | 12,000 mAh |
| Maximum Operating Time | Up to 2 hours |
| Maximum Operating Time in Minutes | 120 minutes |
| Quick-Release Battery | Supported |
| Swappable Battery Grip | Supported |
| External Power Supply | Supported |
| Operation While Charging | Supported |
| USB Power Delivery | 65 W PD |
| Power Connection | USB Type-C |
| Extended Field Operation | Supported through battery replacement or compatible external power supply |
| Additional Battery Compatibility | Compatible Raven series battery grip |
| Operating Time Conditions | Actual operating time depends on scanning conditions, accessories and battery condition |
Physical Specifications
| Scanner Dimensions | 148 × 288 × 98 mm |
|---|---|
| Scanner Dimensions in Centimeters | 14.8 × 28.8 × 9.8 cm |
| Specified Scanner Weight | 1.1 kg |
| Scanner Weight in Grams | 1,100 g |
| RTK Kit Weight | Not separately specified by manufacturer |
| Combined Scanner and RTK Configuration Weight | Depends on installed RTK accessories; 1.1 kg is the published scanner weight |
| Design | Portable handheld scanner with detachable battery grip and RTK positioning expansion |
| Color | Gray and black |
| Battery Handle | Removable |
| Scanner Mounting | Compatible with dedicated mounting accessories |
| Handheld Operation | Supported |
| Portable Field Operation | Supported |
| Transport Protection | Dedicated carrying case included |
Operating Environment and Laser Safety
| Recommended Operating Temperature | 0°C to +35°C |
|---|---|
| Recommended Operating Temperature (Fahrenheit) | 32°F to 95°F |
| Low-Temperature Tolerance | Manufacturer indicates possible tolerance down to approximately -10°C under extreme conditions; sub-zero operation is not recommended |
| Indoor Operation | Supported |
| Outdoor Operation | Supported |
| Low-Light LiDAR Operation | Supported |
| Nighttime LiDAR Scanning | Supported |
| Low-Light RGB Capture | Dependent on ambient lighting |
| Laser Wavelength | 905 nm |
| Laser Safety Classification | Class 1 |
| Laser Safety Standard | IEC 60825-1:2014 |
| Ingress Protection Rating | Not specified by manufacturer |
| Waterproof Rating | Not specified by manufacturer |
| RTK Satellite Reception | Requires adequate GNSS satellite visibility for reliable positioning |
3D Reconstruction and Data Processing
| 3D Point Cloud Generation | Supported |
|---|---|
| RGB Colorized Point Clouds | Supported |
| Monochrome Point Clouds | Supported |
| Georeferenced Point Cloud Generation | Supported using RTK positioning |
| Polygonal 3D Model Reconstruction | Supported through compatible processing workflows |
| Colorized Polygon Models | Supported |
| 3D Gaussian Splatting | Supported |
| Gaussian Splatting Export | PLY |
| Color Point Cloud Export | PLY and other supported point cloud formats |
| Polygonal Model Export | OBJ |
| 4K Visual Reconstruction | Supported through integrated camera data |
| Color Texture Mapping | Supported |
| Large-Scale Scene Reconstruction | Supported |
| Indoor Environment Reconstruction | Supported |
| Outdoor Environment Reconstruction | Supported |
| Digital Twin Data Creation | Supported |
| Geospatial 3D Data Processing | Supported through georeferenced point cloud export and compatible GIS software |
| Online 3D Scene Publishing | Supported through compatible JIMUMETA workflows |
| Gaussian Splatting GPU Requirement | NVIDIA GPU required for the manufacturer's processing workflow |
Supported File Formats
| File Format | Data Type | Application |
|---|---|---|
| LAS | LiDAR point cloud | Surveying, GIS, geospatial analysis and point cloud processing |
| PCD | Point cloud data | 3D point cloud analysis and processing |
| PLY | 3D point cloud, RGB point cloud and Gaussian Splatting data | 3D visualization, colorized spatial data and reconstruction |
| OBJ | Polygonal 3D model | 3D modeling, mesh visualization and compatible CAD workflows |
| E57 | Standardized 3D point cloud exchange | Surveying, laser scanning and point cloud interoperability |
| XYZ | 3D coordinate point data | Spatial coordinate analysis and point cloud exchange |
| LAZ | Compressed LiDAR point cloud | Referenced in manufacturer software compatibility information; availability may depend on RayStudio version |
Software and Data Processing
| Official Desktop Software | 3DMakerpro RayStudio |
|---|---|
| Software Functions | Point cloud processing, inspection, optimization, reconstruction and export |
| Point Cloud Visualization | Supported |
| Color Point Cloud Processing | Supported |
| Point Cloud Denoising | AI-assisted one-click denoising |
| Point Cloud Optimization | Supported |
| 3D Model Reconstruction | Supported |
| Gaussian Splatting Processing | Supported |
| GPU Acceleration | NVIDIA GPU required for Gaussian Splatting |
| Georeferenced Point Cloud Processing | Supported through RTK-enabled scanning and compatible post-processing workflows |
| Point Cloud Data Export | Supported |
| CAD and BIM Data Exchange | Supported through compatible exported formats and third-party conversion workflows |
| Online Visualization Platform | JIMUMETA |
| Online Panoramic Project Hosting | Supported through compatible JIMUMETA services |
| Online Gaussian Splatting Hosting | Supported through compatible JIMUMETA services |
| Online Project Sharing | Supported through compatible JIMUMETA workflows |
Computer System Requirements
| Component | Minimum Configuration | Recommended Configuration |
|---|---|---|
| Processor | Intel Core i7 | Intel Core i7 or better |
| System Memory | 32 GB RAM | 64 GB RAM |
| Graphics Card | NVIDIA GeForce RTX 3060 | NVIDIA RTX 4060 as listed by manufacturer |
| Graphics Memory | 8 GB VRAM | 16 GB VRAM specified by manufacturer; verify memory capacity of the selected GPU |
| Operating System | Windows 11 or later in published specifications | Windows 11 or later |
| Gaussian Splatting GPU | NVIDIA GPU required | NVIDIA GPU with higher available VRAM |
Operating System and Third-Party Compatibility
| Official Processing Platform | Microsoft Windows |
|---|---|
| Published Operating System Requirement | Windows 11 or later |
| Windows 10 Compatibility | Also mentioned in the manufacturer's RayStudio FAQ for 64-bit systems; confirm against the installed software version |
| macOS Compatibility | Not supported by published RayStudio specifications |
| NVIDIA GPU Requirement | Required for Gaussian Splatting processing |
| CloudCompare | Compatible through supported point cloud exchange formats |
| Leica Cyclone | Compatible through supported point cloud import workflows |
| FARO Scene | Compatible through supported point cloud import workflows |
| Trimble RealWorks | Compatible through supported point cloud import workflows |
| Autodesk AutoCAD | Compatible through supported point cloud and 3D model workflows |
| Autodesk Revit | Compatible through supported scan-to-BIM conversion and point cloud workflows |
| GIS Software Compatibility | Supported through compatible georeferenced point cloud formats such as LAS and E57; direct integration depends on the target GIS software |
Supported Scanning Configurations
| Handheld Scanning | Supported |
|---|---|
| Stationary Scanning | Supported with a suitable holder or mounting arrangement |
| Outdoor RTK-Assisted Scanning | Supported |
| Indoor SLAM Scanning | Supported without GNSS positioning |
| Georeferenced Mobile Mapping | Supported |
| Bicycle-Mounted Scanning | Supported with optional Bicycle Kit |
| Motorcycle-Mounted Scanning | Supported with suitable mounting equipment |
| Vehicle-Mounted Scanning | Supported with optional Automotive Rooftop Mount |
| Backpack-Mounted Scanning | Supported with optional Backpack Kit |
| Drone-Mounted Scanning | Supported with suitable custom mounting arrangements |
| Drone Payload Requirement | Must accommodate scanner weight, RTK hardware, mounting equipment and other required accessories |
| Drone Flight Controller Integration | Not required for independent scanner operation |
| External 360° Camera Mounting | Supported through optional 360 Camera Kit |
| Battery-Powered Field Scanning | Supported |
| External-Power Scanning | Supported |
Professional Applications
| Land Surveying | RTK-referenced spatial mapping and 3D point cloud acquisition |
|---|---|
| Topographic Surveying | Terrain, surface and site data capture |
| Geospatial Mapping | 3D data capture associated with geographic coordinates |
| GIS Data Collection | Georeferenced 3D spatial datasets for compatible GIS workflows |
| Construction Surveying | Construction site scanning, progress documentation and as-built reference data |
| Architecture | Architectural geometry, building interiors, facades and existing-condition capture |
| Building Information Modeling | Point cloud acquisition for scan-to-BIM and building documentation |
| Infrastructure Mapping | Roads, structures, utilities and infrastructure asset documentation |
| Urban Mapping | Outdoor 3D mapping and georeferenced urban environment capture |
| Civil Engineering | Spatial documentation and 3D site data acquisition |
| Facility Management | 3D documentation of buildings and infrastructure facilities |
| Real Estate | Property scanning, interactive 3D visualization and virtual tours |
| Digital Twin Creation | Georeferenced spatial datasets for digital twin workflows |
| Geological Mapping | Rock formations, caves and geological site documentation |
| Underground Mapping | Tunnels, caves and enclosed underground environments using SLAM |
| Cultural Heritage | 3D documentation and digital preservation of historical structures and sites |
| Environmental Surveying | Spatial mapping of outdoor environments and natural features |
| Forensics and Public Safety | 3D spatial documentation of incident locations |
| Media and Virtual Production | 3D environment capture and Gaussian Splatting reconstruction |
| Game Development | Real-world environment capture for digital scene creation |
Raven Max RTK Package Contents
| Item | Quantity | Notes |
|---|---|---|
| 3DMakerpro Raven Max LiDAR Scanner | 1 | Dual 12 MP camera scanner |
| RTK GNSS Kit | 1 | Positioning expansion kit for georeferenced scanning |
| Battery Grip | 1 | 12,000 mAh rechargeable battery grip |
| Holder Base | 1 | Scanner support and mounting base |
| Protective Cover | 1 | Protective cover for scanner optics |
| TF Card | 1 | 128 GB removable storage card |
| TF Card Reader | 1 | For transferring recorded scanning data |
| Carrying Case | 1 | Dedicated protective engineering transport case |
Optional Accessories and Expansion
| Additional Battery Grip | Compatible quick-release battery grip for extended field operation |
|---|---|
| 360 Camera Kit | Mounting solution for compatible panoramic cameras |
| Insta360 X4 | Supported with compatible 360 Camera Kit |
| Insta360 X5 | Supported with compatible 360 Camera Kit |
| Bicycle Kit | Mounting equipment for bicycle and compatible motorcycle scanning |
| Automotive Rooftop Mount | Vehicle-mounted 3D data acquisition accessory |
| Backpack Kit | Wearable mounting solution for mobile scanning |
| Drone Mounting Accessories | Custom mounting solutions for compatible UAV platforms |
| Additional TF Cards | Removable data storage expansion |
| RTK GNSS Kit | Already included with Raven Max RTK configuration |
Technical Documentation
| Product Brochure | 3DMakerpro Raven Series Brochure (PDF) |
|---|---|
| Official Manufacturer Specifications | 3DMakerpro Raven Series Technical Specifications |
| Product Reference | 3DMakerpro Raven Max RTK – Global GPS Systems |
Specifications and package contents may vary by configuration, region or manufacturer update. Always check the current configuration before ordering.
Reviews (0)
Only logged in customers who have purchased this product may leave a review.
FAQ
3DMakerpro Raven Max RTK LiDAR 3D Scanner FAQ
General Information and Applications
What is the 3DMakerpro Raven Max RTK LiDAR 3D Scanner?
The 3DMakerpro Raven Max RTK is a portable handheld SLAM LiDAR 3D scanner equipped with a dual 12MP camera system and an RTK GNSS expansion kit. It combines LiDAR distance measurements, Simultaneous Localization and Mapping (SLAM) technology and satellite positioning to capture detailed 3D point clouds and support georeferenced mapping workflows. With a manufacturer-specified scanning range of 80 to 100 meters, a point acquisition rate of up to 150,000 points per second and 360-degree horizontal scanning coverage, the Raven Max RTK is designed for surveying, construction, architecture, infrastructure documentation and digital twin creation.
What is the 3DMakerpro Raven Max RTK used for?
The Raven Max RTK is used for mobile 3D mapping, topographic documentation, construction site surveys, architectural measurements, building documentation, infrastructure inspection, as-built modeling and digital twin creation. Its combination of SLAM LiDAR and RTK GNSS positioning is particularly useful for outdoor projects where point clouds must be associated with real-world coordinates. Professionals can capture spatial data while walking through an environment and process the resulting point clouds for measurements, CAD and BIM workflows, engineering analysis and visualization.
Which industries benefit from the 3DMakerpro Raven Max RTK?
The 3DMakerpro Raven Max RTK is suitable for land surveying, geospatial mapping, architecture, engineering, construction (AEC), infrastructure management, industrial manufacturing, facility management, real estate and cultural heritage documentation. Surveyors can use it to capture georeferenced 3D data, engineers to document infrastructure, architects to create existing-condition models and construction professionals to record project progress. The dual-camera system also supports realistic color reconstruction for digital twins and immersive visualization.
What is the difference between the 3DMakerpro Raven, Raven Max and Raven Max RTK?
The three Raven configurations share the same core SLAM LiDAR scanning platform, with a scanning range of up to 100 meters, 360-degree horizontal coverage and a point acquisition rate of up to 150,000 points per second. The standard Raven features one 12MP camera, while the Raven Max uses two 12MP cameras for additional color imaging coverage. The Raven Max RTK combines the dual-camera configuration with an RTK GNSS expansion kit for georeferenced mapping workflows. It is the most suitable configuration in the Raven series for projects requiring both detailed 3D scanning and satellite-based positioning.
Can the Raven Max RTK scan both indoor and outdoor environments?
Yes. The 3DMakerpro Raven Max RTK supports indoor and outdoor 3D scanning. It can capture building interiors, warehouses, corridors, construction sites, building facades, industrial facilities and outdoor infrastructure. SLAM technology enables scanning in environments where GNSS signals are unavailable, while the RTK positioning system can provide geographic positioning information in suitable outdoor conditions. RTK performance depends on satellite visibility, correction availability and environmental conditions, so GNSS positioning may be limited inside buildings, underground or beneath dense obstructions.
Is the Raven Max RTK suitable for topographic surveying and construction site mapping?
Yes. The Raven Max RTK can support topographic documentation, construction site mapping, earthworks surveys, site condition assessments and infrastructure documentation. Its handheld SLAM system allows operators to collect dense 3D point clouds while moving, and the RTK expansion kit supports positioning the captured data within a geographic coordinate system. For topographic and engineering projects requiring specific absolute accuracy tolerances, users should apply appropriate survey control, coordinate transformation and independent validation procedures.
RTK GNSS, SLAM and Georeferencing
What is RTK GNSS and how does it work with the Raven Max RTK?
RTK stands for Real-Time Kinematic, a GNSS positioning technique that uses correction data from a reference station or correction network to improve satellite positioning accuracy. The Raven Max RTK uses a compatible RTK expansion kit alongside its SLAM LiDAR scanning system. While SLAM estimates the scanner's movement and creates a 3D map of the environment, RTK provides geographic positioning information under suitable conditions. Combining the two technologies helps associate captured 3D point clouds with real-world coordinates for surveying, construction and geospatial applications.
How accurate is the RTK positioning system on the Raven Max RTK?
The Raven Max RTK supports high-precision GNSS positioning through its RTK expansion kit, but the absolute accuracy of a completed georeferenced point cloud depends on several factors. These include satellite reception, correction quality, RTK solution status, antenna configuration, SLAM alignment, coordinate transformation and processing procedures. Centimeter-level GNSS positioning may be achievable under suitable RTK conditions, but this should not be interpreted as a guaranteed centimeter-level accuracy specification for every point in the final 3D scan. Projects requiring certified survey accuracy should use independent control measurements.
Does the 3DMakerpro Raven Max RTK require an internet connection or NTRIP corrections?
RTK positioning requires suitable correction data, which may be provided by an NTRIP correction service or a compatible local GNSS reference station, depending on the supported RTK workflow. An internet connection is commonly required when receiving corrections from an online NTRIP network. However, the Raven Max RTK can still collect LiDAR and SLAM data without an active RTK correction connection. In that situation, the scanning workflow can continue, but RTK-based georeferencing accuracy may be reduced or unavailable. Users should verify the supported correction methods and connectivity requirements for their configuration.
Can the Raven Max RTK generate georeferenced 3D point clouds?
Yes. The Raven Max RTK is designed to support georeferenced point cloud workflows by combining SLAM LiDAR measurements with RTK GNSS positioning. Georeferencing associates scanned 3D geometry with real-world coordinates, making the data useful for surveying, GIS, construction planning and infrastructure documentation. The final coordinate accuracy depends on GNSS observations, correction data, coordinate system configuration and the processing workflow. Users should verify that the selected project coordinate system and exported point cloud coordinates meet their requirements.
Can the Raven Max RTK scan indoors when GPS or GNSS signals are unavailable?
Yes. The Raven Max RTK uses SLAM technology to track scanner movement and build 3D point clouds without requiring continuous GNSS reception. This allows it to scan indoor environments such as warehouses, factories, corridors and building interiors. When transitioning between outdoor and indoor areas, suitable GNSS observations, overlapping scan geometry and survey control can help maintain the relationship between the captured point cloud and a geographic coordinate system. Long scans without external positioning constraints may experience accumulated SLAM drift.
What is the difference between SLAM positioning and RTK positioning?
SLAM and RTK perform different but complementary functions. SLAM, or Simultaneous Localization and Mapping, estimates the scanner's movement relative to its surroundings while creating a 3D map. RTK uses satellite signals and correction data to calculate positions within a geographic reference system. SLAM is especially useful for mobile scanning indoors and in GNSS-obstructed environments, while RTK supports accurate geographic positioning in suitable outdoor conditions. The Raven Max RTK combines these technologies to support both mobile 3D mapping and georeferenced spatial data collection.
LiDAR Accuracy, Cameras and Field Performance
How accurate is the 3DMakerpro Raven Max RTK LiDAR scanner?
The 3DMakerpro Raven Max RTK has a manufacturer-specified LiDAR ranging accuracy of 2 cm at 10 meters, 3 cm at 20 meters and 5 cm at 40 meters. These values describe the distance measurement performance of the LiDAR sensor rather than the absolute accuracy of an entire georeferenced survey. Actual 3D point cloud accuracy depends on scanning distance, surface reflectivity, scanner movement, SLAM alignment, environmental conditions and post-processing. For engineering or surveying applications with strict tolerances, independent accuracy verification is recommended.
What is the maximum scanning range of the 3DMakerpro Raven Max RTK?
The 3DMakerpro Raven Max RTK has a manufacturer-specified LiDAR scanning range of 80 to 100 meters. Its effective scanning radius is approximately 40 meters for surfaces with 10% reflectivity and 50 meters for surfaces with 80% reflectivity. Maximum usable distance depends on target reflectivity, atmospheric conditions, scanning geometry and visibility. The scanner has a minimum measuring distance of approximately 0.5 meters, making it suitable for both indoor building documentation and larger outdoor mapping applications.
How fast does the Raven Max RTK capture 3D point clouds?
The Raven Max RTK captures up to 150,000 LiDAR points per second. This acquisition rate enables continuous spatial data collection while the operator moves through an environment. The combination of LiDAR scanning and SLAM algorithms allows professionals to document buildings, infrastructure and construction sites without repeatedly moving and setting up a stationary terrestrial laser scanner. The time required to complete a survey depends on project size, scanning route, accessibility, required detail and the complexity of the environment.
What is the scanning field of view of the Raven Max RTK?
The 3DMakerpro Raven Max RTK provides 360-degree horizontal scanning coverage and a 40-degree vertical field of view. The 360-degree horizontal coverage allows the scanner to record surrounding geometry while moving through an environment. Its vertical scanning angle captures walls, floors, structures and surrounding objects within the sensor's viewing area. Additional passes or adjustments to scanner orientation may be required to capture ceilings, elevated surfaces or areas hidden behind obstacles.
What is the advantage of the dual 12MP cameras on the Raven Max RTK?
The Raven Max RTK features two 12MP cameras with 1/2-inch image sensors. The dual-camera configuration provides additional visual coverage for color reconstruction compared with the single-camera standard Raven. Camera imagery can be combined with LiDAR measurements to create RGB-colored point clouds and realistic representations of scanned environments. This is particularly useful for architectural documentation, digital twins, construction visualization, infrastructure inspection and immersive presentations. The cameras provide color information, while the LiDAR system supplies the primary geometric measurements.
How long does the Raven Max RTK battery last?
The 3DMakerpro Raven Max RTK uses a removable 12,000 mAh battery grip that provides up to approximately two hours of operation under the manufacturer's stated conditions. The scanner supports an external power supply through a 65W USB-C Power Delivery connection, including operation while connected to suitable external power. Actual operating time depends on environmental conditions, scanner settings, connected accessories and the RTK configuration. The removable battery design supports longer field operations when additional compatible batteries are available.
How portable is the Raven Max RTK and can it be mounted on other platforms?
The Raven Max scanning unit weighs approximately 1.1 kg and measures 148 x 288 x 98 mm, excluding the additional weight and dimensions of the RTK expansion equipment. Its portable design makes it suitable for handheld mapping and field surveying. The Raven platform also supports compatible accessories for backpack, bicycle, vehicle and drone mounting configurations. Specialized mobile mapping applications require appropriate mechanical mounting, power arrangements, GNSS antenna placement and verification of scanning performance under movement or vibration.
Software, Data Export and Professional Workflows
What software is used with the 3DMakerpro Raven Max RTK?
The 3DMakerpro Raven Max RTK uses RayStudio, the manufacturer's processing software for Raven LiDAR scanning data. RayStudio supports point cloud processing, visualization, color reconstruction, model generation and compatible Gaussian Splatting workflows. The processed data can be exported in several professional 3D file formats for use in surveying, engineering, CAD, BIM and visualization applications. Georeferenced projects also require appropriate handling of positioning data, coordinate systems and the supported RTK processing workflow.
Which point cloud and 3D file formats can the Raven Max RTK export?
The 3DMakerpro Raven Max RTK supports data export in LAS, PCD, PLY, OBJ, E57 and XYZ formats. LAS and E57 are commonly used for surveying, LiDAR point clouds and geospatial documentation. PCD and XYZ support point cloud processing and analysis, while PLY and OBJ are frequently used for 3D modeling and visualization. The available formats depend on the selected processing and export workflow. Users working with georeferenced projects should verify that the coordinate system and spatial reference information are correctly preserved during export and conversion.
Can Raven Max RTK point clouds be used in AutoCAD, Revit, CloudCompare and GIS software?
Yes. Raven Max RTK point clouds can be processed and transferred to compatible CAD, BIM and GIS applications using supported file formats. CloudCompare can work with common point cloud formats, while Autodesk AutoCAD and Revit workflows may require additional conversion or indexing through software such as Autodesk ReCap. GIS applications that support georeferenced LAS or other compatible spatial formats can also be used for further analysis. Compatibility depends on the software version, import settings, coordinate system and selected export format.
Can the Raven Max RTK be used for scan-to-BIM, as-built models and digital twins?
Yes. The Raven Max RTK can capture detailed spatial data for scan-to-BIM workflows, as-built building documentation and digital twin creation. Its SLAM LiDAR system records existing geometry, the dual 12MP cameras provide color information and RTK positioning supports geographic referencing in suitable environments. Architects, engineers and construction professionals can use processed point clouds as reference data for creating CAD and BIM models. Generating engineering-grade BIM elements or interactive digital twins generally requires additional modeling software, quality control and project-specific data processing.
Does the 3DMakerpro Raven Max RTK support Gaussian Splatting and virtual tours?
Yes. The Raven Max RTK supports Gaussian Splatting workflows through RayStudio software. Gaussian Splatting is a 3D visualization technique that uses captured imagery and spatial information to create realistic representations of physical environments. It is useful for virtual property tours, architectural visualization, immersive experiences, digital twins and cultural heritage documentation. The dual 12MP camera system provides image data for visual reconstruction. Gaussian Splatting processing requires a compatible NVIDIA GPU, and visualization outputs should not replace validated survey geometry when precise measurements are required.
What computer specifications are required to process Raven Max RTK scans?
The manufacturer's published minimum processing requirements include an Intel Core i7 processor, 32 GB RAM and an NVIDIA RTX 3060 graphics card with 8 GB VRAM. The recommended configuration includes an Intel Core i7 processor, 64 GB RAM and an NVIDIA RTX 4060 graphics card with 16 GB VRAM. The supported operating system is Windows 11 or later, and native macOS compatibility is not listed. Gaussian Splatting processing requires an NVIDIA GPU. Large georeferenced point clouds and complex reconstruction projects may benefit from additional RAM, graphics performance and high-speed storage.
Videos
 GPS & GNSS
 Total Stations
 Data collectors
 Software
 Correction services
 Machine control
 External radio
 Marine
 Accessories
Reviews
There are no reviews yet